6-DoF trajectory
Position + orientation through time.
Sento turns skilled physical work into training data for physical AI.
We capture the physical signals behind real tasks while people do the work they already know how to do. Diverse demonstrations, grounded in the real world.
Forces change. Tools rotate. Contact begins and breaks. There’s more to skilled work than meets the eye.
It starts at the surface.
A familiar task. A world of physical information. Look closer at what happens when a tool meets a material.
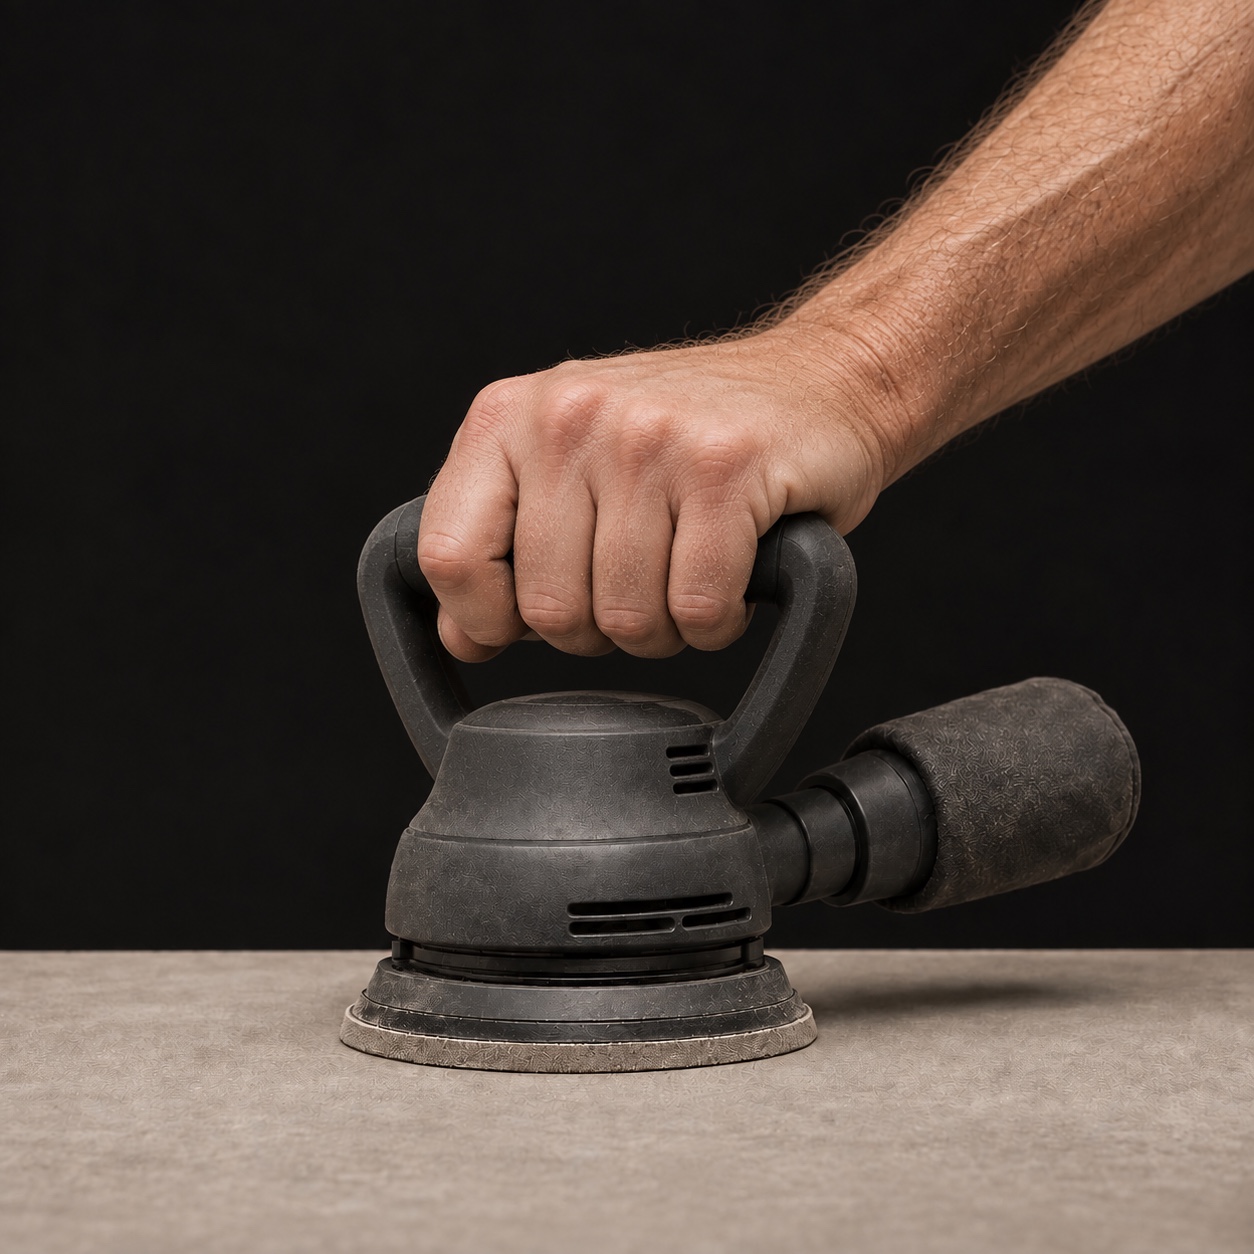
Position + orientation through time.
How strongly the tool engages the environment.
How resistance changes through the task.
When engagement begins, changes, and ends.
One task. More of the physical world.
Different methods serve different purposes. Sento brings richer physical supervision to the scale and variety of real work.
| Collection capabilities | Sento | Video only | Wearables | Robot teleoperation |
|---|---|---|---|---|
| Natural real-world work | Yes | Yes | Limited | Limited |
| Tool motion / trajectory | Yes | Limited | Varies | Direct |
| Force | Yes | No | Limited | Yes |
| Torque | Yes | No | No | Yes |
| Contact state | Yes | Limited | Limited | Yes |
| Robot required for collection | No | No | No | Yes |
| Fits existing skilled workflow | Yes | Yes | Limited | Limited |
| Scalability | Very Strong | Strong | Moderate | Low |
* Exact capabilities vary by collection hardware and implementation.
We work backward from the behavior your model needs to learn.
TASK SPECIFICATIONSkilled workers perform real tasks in real environments.
REAL-WORLD DEMONSTRATIONSPhysical signals and task context are synchronized, segmented, and validated.
ALIGNED + VALIDATEDReceive training-ready data in a schema designed for your pipeline.
STRUCTURED DELIVERYDefine the skills, environments, and physical signals you need. We coordinate collection around your training objective.
Keep doing the work you already know. You shouldn’t have to become a robot operator to teach a robot what expert work looks like.
Collection should scale with useful data—not with the number of rigs you can operate.
For teams validating a new data source.
For ongoing training-data programs.
For continuous or specialized collection.
Tell us the task.
We’ll design the collection.